Computability of Extender Sets in Multidimensional Subshifts

Abstract
Subshifts are sets of colorings of defined by families of forbidden patterns. Given a subshift and a finite pattern, its extender set is the set of admissible completions of this pattern. It has been conjectured that the behavior of extender sets, and in particular their growth called extender entropy [10], could provide a way to separate the classes of sofic and effective subshifts. We prove here that both classes have the same possible extender entropies: exactly the real numbers of .
Keywords and phrases:
Symbolic dynamics, subshifts, extender sets, extender entropy, computability, sofic shifts, tilingsCopyright and License:
 © Antonin Callard, Léo Paviet Salomon, and Pascal Vanier; licensed under Creative Commons License CC-BY 4.0
2012 ACM Subject Classification:
Mathematics of computing Discrete mathematics ; Theory of computation Models of computationAcknowledgements:
We are thankful to the referees for their many helpful remarks and suggestions.Funding:
This research was partially funded by ANR JCJC 2019 19-CE48-0007-01.Editors:
Olaf Beyersdorff, Michał Pilipczuk, Elaine Pimentel, and Nguyễn Kim ThắngSeries and Publisher:
 Leibniz International Proceedings in Informatics, Schloss Dagstuhl – Leibniz-Zentrum für Informatik
1 Introduction
In dimension , subshifts are sets of colorings of where a family of patterns, i.e. colorings of finite portions of , have been forbidden. They were originally introduced to discretize continuous dynamical systems [19]. One of the main families of subshifts that has been studied is the class of subshifts of finite type (SFTs), which can be defined with a finite family of forbidden patterns. This class has independently been introduced under the formalism of Wang tiles [25] in dimension 2 in order to study fragments of second order logic.
In dimension 1, sofic subshifts [26], which are obtained as letter-to-letter projections of SFTs, are studied mainly through their defining graphs. In dimension 2 and higher, SFTs (and thus sofic subshifts) can embed arbitrary Turing machine computations; as such, the main tool in the study of subshifts becomes computability theory. This led to the introduction of a new class of subshifts, the effective subshifts, which can be defined by computably enumerable families of forbidden patterns [13].
An important question in symbolic dynamics is thus to find criteria separating sofic from effective subshifts [15, 22, 12, 3]. In dimension 1, a subshift is sofic if it can be defined by a regular language of forbidden patterns: the Myhill–Nerode theorem states that these are exactly the languages that have finitely many Nerode congruence classes. In dimension 2 and higher, no such clear characterization exists. Indeed, many effective subshifts have been proved to be sofic, such as substitutive subshifts [20], or effective subshifts on whose densities of symbols 1 are sublinear [6]; it even turns out that sofic subshifts of dimension capture all the behaviors of effective shifts of dimension [13, 8, 2].
All the methods used to prove some cases of non-soficity that are known by the authors revolve around a counting argument: only a linear amount of information may cross the border of an square pattern (see for example [1, Proposition 9.4.5]). The most recent argument in this vein uses resource-bounded Kolmogorov complexity [7].
One formalization of this counting argument relies on extender sets of patterns [15], which can be considered as a higher-dimensional generalization of Nerode congruence classes: the extender set of a pattern is the set of all configurations with a -shaped hole that may extend . For SFTs, the extender set of a given pattern is entirely determined by its boundary, which implies that the number of extender sets of an SFT cannot grow too quickly. For subshifts in dimension 1, [21, Lemma 3.4] proves the analog of Myhill-Nerode theorem: a subshift is sofic if and only if its number of extender sets of every size is bounded. In dimension 2 and higher, only sufficient conditions are known: for example, a subshift whose number of extender sets for patterns of size is bounded by must be sofic [21].
The study of the growth rate of the number of extender sets can be done asymptotically through the notion of the extender entropy, which is defined in a similar way to the classical notion of topological entropy [17]. Extender entropies in fact relate to the to notion of follower entropies [4], but are more robust in the sense that, despite it not being decreasing under factor map applications, the extender entropy of a subshift is still a conjugacy invariant.
In this paper, we achieve characterizations of the possible extender entropies in terms of computability, in the same vein as recent results on conjugacy invariants of subshifts [14, 18].
Theorem A.
The set of extender entropies of effective subshifts is exactly .
Theorem B.
The set of extender entropies of sofic subshifts is exactly .
These results generalize to dimension by Claim 8 and Corollary 12. While sofic subshifts were conjectured in [15] to have extender entropy zero, this was later disproved (see for example [7]); in fact, our characterization shows that the possible values are dense in . This also proves that extender entropies do not separate sofic from effective shifts.
| SFT | (Folklore: see Proposition 6) | |
|---|---|---|
| Sofic | ([9, Theorem 1.1]) | (B) |
| Effective | (A) | |
| Computable ( effective, sofic) | (Theorem 27) | |
| Sofic and minimal | (Corollary 29) | |
| Effective and minimal | (Corollary 30) | |
| Effective and -Mixing/Block-Gluing | (Proposition 32) | (Proposition 34) |
Finally, we also study extender entropies of subshifts constrained by some dynamical assumptions, such as minimality or mixingness. What is known by the authors at this stage can be summed up by the table Figure 1.
2 Definitions
2.1 Subshifts
Let denote a finite set of symbols and the dimension. A configuration is a coloring , and the color of at position is denoted by . A (-dimensional) pattern over is a coloring for some set called its support111It is sometimes convenient to consider patterns up to the translation of their support. Usually, context will make it clear whether patterns are truly equal, or only up to a translation.. For any pattern over of support , we say that appears in a configuration (and we denote ) if there exists such that for all .
The shift functions act on configurations as . For , a configuration is -periodic if . We sometimes consider patterns or configuration by their restriction: for either finite or infinite, and a configuration (resp. a pattern), we denote by (resp. ) the coloring of it induces on .
Definition 1 (Subshift).
For any family of finite patterns , we define
A set is called a subshift if it is equal to some .
Given a subshift and a finite support , we define as the set of patterns of support that appear in the configurations of . Such patterns are said to be globally admissible in . We define the language of as . Slightly abusing notations, we denote for .
For and two subshifts, is a factor map if there exists some and such that : then is a factor of . and are conjugate if there exists a bijective factor map (called a conjugacy). Any object associated with subshifts that is preserved by conjugacy is a conjugacy invariant.
Subshifts can be classified as follows: a subshift is of finite type (SFT) if it is equal to for some finite family of forbidden patterns; a subshift is effective if it is equal to for some computably enumerable family of forbidden patterns; and a subshift is sofic if it is a factor of some SFT, called its SFT cover. SFTs are sofic by definition, and sofic subshifts are effective.
Reciprocally, for a subshift , define the following lifts:
-
the periodic lift , where for all ;
-
the free lift .
If is sofic (resp. effective), then both and are also sofic (resp. effective) since they can be defined by the same forbidden patterns. On the other hand:
Theorem 2 ([13], [2, Theorem 3.1], [8, Theorem 10]).
If is an effective subshift, then is a sofic subshift.
Finally, most of our constructions will involve the notion of layers: for a subshift of a cartesian product , the layers of are the projections of onto each of the , which are often named for convenience. For , we will denote by the cartesian projection.
2.2 Pattern Complexity and Extender Sets
The traditional notion of complexity is called pattern complexity and is defined by . The exponential growth rate of is the topological entropy:
In this article, we focus on another notion of complexity based on extender sets:
Definition 3 (Extender set).
For a -dimensional subshift, and a pattern of support , the extender set of is the set
where if and otherwise.
In other words, is the set of all possible valid “completions” of the pattern in . For example, for two patterns with the same support , we have if and only if the pattern can be replaced by every time it appears in any configuration of .
In the case of subshifts, extender sets are similar to the more classical notions of follower (resp. predecessor) sets, which are the set of right-infinite (resp. left-infinite) words that complete a finite given pattern (see for example [9]). Parallels can also be drawn with Nerode congruence classes.
For a subshift, denote its set of extender sets. The extender set sequence and its growth rate222The authors define it for subshifts, but the definition makes sense for higher dimensional shifts. are defined in [9]:
Definition 4 ([10, Definition 2.17]).
For a subshift , its extender entropy is
This limit is well-defined by the multivariate subadditive lemma (see [5, Theorem 1]). In particular, , and could actually be computed along any sequence of hyperrectangles that eventually fills .
Examples
-
1.
Let us consider some full-shift in dimension . Then has maximal topological entropy, but : indeed, for any two patterns , we have ; which implies that for every .
-
2.
Let us consider a (strongly) periodic subshift: there exist such that, for every and , we have . Then has zero topological entropy, and we also have . Indeed, for and , is the only pattern such that ; so that for .
Some Properties
Theorem 5 (From [10] on subshifts).
On subshifts:
-
is a conjugacy invariant.
-
is not necessarily decreasing under factor map.
-
is additive under product (i.e. for two subshifts, ).
-
is upper bounded by (i.e. for a subshift, ).
For SFTs, the following proposition is folklore:
Proposition 6 ([15, Section 2]).
Let be a -dimensional SFT. Then .
Sketch of proof.
In an SFT defined by adjacency constraints, the extender set of a pattern is determined by its border; and there are at most such borders. By an analog of the Myhill-Nerode theorem, sofic subshifts have extender entropy zero:
Proposition 7 ([21, Lemma 3.4]).
Let be a -dimensional subshift. Then is sofic if and only if is uniformly bounded.
2.3 Computability Notions
2.3.1 Arithmetical Hierarchy
The arithmetical hierarchy [24, Chapter 4] stratifies formulas of first-order arithmetic over by the number of their alternating unbounded quantifiers: for , define
A decision problem is said to be in (resp. ) if its set of solutions is described by a (resp. ) formula: in other words, corresponds to the set of computable decision problems; is the set of computably enumerable decision problems, etc…
2.3.2 Arithmetical Hierarchy of Real Numbers
The arithmetical hierarchy of real numbers [27] stratifies real numbers depending on the difficulty of computably approximating them: for , define
In particular, is the set of computable real numbers, i.e. numbers that can be computably approximated up to arbitrary precision; real numbers are also called right-computable, since they can be computably approximated from above; etc…
Alternatively, this hierarchy is also defined by the number of alternating limit operations needed to obtain a real number from the computable ones [27]. In other words, for :
3 Elementary Constructions on Extender Sets
The free lift
We use this construction to generalize results on or subshifts to higher dimensions:
Claim 8.
For a subshift , .
Proof.
Consider . Since each -dimensional hyperplane of contains an independent configuration, we have and .
The (semi)-mirror construction
Claim 9.
Let be any sofic subshift over an alphabet . There exists a sofic subshift such that ().
A first idea to create one extender set per pattern of is the mirror construction: add a line of some special symbol to separate two half-planes; the upper half-plane contains a half-configuration of , while the lower half-plane contains its reflection by the line of . As any two patterns of have distinct reflections, they generate different extender sets: this results in a subshift verifying . Unfortunately, is not always sofic, see for example [1, Proposition 57].
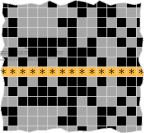
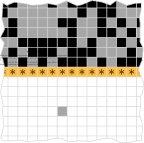
To solve this non-soficness issue, the semi-mirror with large discrepancy from [7, Example ] reflects a single symbol instead of the whole upper-plane:
Sketch of proof.
For , define over the alphabet as follows:
-
Symbols must be aligned in a row, and there is at most one such row per configuration.
-
If a row of appears in a configuration , then the lower half-plane contains at most one non- position; and the upper half-plane must appear in a configuration of .
-
If and for some , then . In other words, the only symbol of in the lower half-plane must be the mirror of the same symbol in the upper half-plane, as reflected by the horizontal row of symbols.
Then is sofic and . Indeed, any two distinct patterns of must appear in and have distinct extender sets, since they can have different reflections.
This construction shows that there exist subshifts with arbitrarily large extender entropy; and since every real number is the topological entropy of some (SFT, thus) sofic subshift [14], every number can be realized as the extender entropy of some sofic subshift. In particular, this further disproves the conjecture from [15] mentioned in the introduction.
4 Decision Problems on Extender Sets
4.1 Inclusion of Extender Sets
Let us consider the following decision problem:
| Extender-inclusion | |
|---|---|
| Input: | An effective subshift , and , |
| Output: | Whether . |
Proposition 10.
Extender-inclusion is a -complete problem.
Proof of inclusion.
As if and only if , we obtain inclusions: indeed, for effective, deciding whether a pattern belongs in is a problem.
Proof of -hardness for subshifts.
We reduce the following known problem333It is equivalent to Inf (does a given machine halt on infinitely many inputs?). See [24, Theorem 4.3.2].:
| Det-Rec-state | |
|---|---|
| Input: | A deterministic Turing Machine , and a state , |
| Output: | Is visited infinitely often by during its run on the empty input? |
Let be an instance of this Det-Rec-state. We construct an effective subshift over the alphabet as follows:
-
Symbols 0 and 1 cannot appear together in a configuration. The symbol 1 can only appear at most once in a configuration.
-
If two symbols 0 appear in a configuration at distance, say, , then the whole configuration is -periodic; and if enters at least times, then we impose .
As the rules above forbid an enumerable set of patterns, is an effective subshift.
Finally, if and only if enters infinitely many times. Indeed, the symbol 0 can be extended either by semi-infinite lines of symbols , which also extend the symbol 1 ; or by configurations containing -periodic symbols 0, which do not extend the symbol 1 because of the first rule. However, by the second rule, this -periodic configuration exists if and only if visits less than times.
4.2 Computing the Number of Extender Sets
Let us determine the computational complexity of the problem “”, when given a subshift , some size and some . It is equivalent to the following:
Since is a problem and that the class of problems is stable by finite disjunctions and conjunctions, we conclude from Proposition 10 that:
Lemma 11.
For an effective subshift , “” is a problem.
4.3 Upper Computational Bounds on Extender Entropies
Corollary 12.
For an effective subshift, .
Proof.
Given and , the set is a set if is effective by Lemma 11. This implies that is ; and since , we obtain as the infimum of real numbers.
5 Extender Entropies for Effective Subshifts
Let us focus on one-dimensional subshifts for the time being.
See A
In order to construct a subshift with , we would like to have . To do so, we could create one extender set per pattern, and patterns of size (as the semi-mirror in Section 3); however, since effective subshifts have entropies, this would not realize the whole class of numbers.
Yet, realizing the right number of patterns is the main idea behind the proof that follows: we just do not blindly create one extender set per pattern, but only separate extender sets when some conditions are met.
5.1 Preliminary: Encoding Integers With Configurations
Before we begin our construction, we fix a way to encode integers in configurations: to encode the integer , we use configurations where a symbol is -periodic, and the rest is blank.
More formally, consider the alphabet . Denote by the -periodic configuration properly defined as if and only if . A configuration is said to encode the integer . Considering the subshift all the configurations for and generate, we denote:
where is the set of configurations having at most one symbol . The configurations of are said to be degenerate, and they appear when taking the closure of all .
5.2 Preliminary: Toeplitz Density in Periodic Configurations
Our construction will also need to build configurations with a controlled density of symbols, i.e. configurations on where the number of symbols in large patterns converges to some value: for some fixed , we want to build configurations such that . Several explicit constructions of such configurations and subshifts exist. We choose to work with Toeplitz sequences.
Toeplitz density words
Consider the ruler sequence defined by (see Oeis A001511). For a given binary sequence , we consider its Toeplitzification defined as for .
In particular, for a real number and its proper binary expansion, we consider the word . Denoting by the numbers of letters in a binary word and by its length, we have:
Claim 13.
For and a factor of , we have .
Toeplitz density in periodic configurations
For our specific construction, let and , and consider the subshift composed of -periodic configurations made of truncated Toeplitz words:
We denote the configuration defined by for . Notice that, for any , and , there are factors of length in .
Claim 14.
Let . Then is an SFT, and a family of forbidden patterns realizing can be computably enumerated from .
Proof.
Consider : the set is computably enumerable. Thus, the following family of forbidden patterns that realizes is recursively enumerable: forbid finite pattern that are either not -periodic, or do not respect the structure of the ruler sequence in an -period; and inside an -period, forbid patterns that encode the finite expansion of a rational if is such that .
5.3 Construction: the Effective Subshift
Let us now begin the construction to prove A. Let be a positive real number, for some computable sequence of real numbers. We can assume since extender entropy is additive under cartesian products, and using [27, Lemma 3.1] we can assume that satisfies some monotonicity properties: for all , is weakly increasing towards some ; and the sequence is weakly decreasing towards .
Auxiliary subshift
We create an auxiliary subshift on the following three layers:
-
1.
First layer : We take to encode integers . Intuitively, will denote which number is approximated in the configuration.
-
2.
Second layer : We also set to encode integers , . Intuitively, will denote which number is approximated in the configuration.
-
3.
Density layer : We define the density layer as . Whenever the first two layers are non-degenerate, this layer will be restricted to densities . Since the real numbers are , the subshifts are effective from the numbers .
such that is defined as:
Claim 15.
The subshift is an effective subshift.
Proof.
Since the subshift is effective, the conditions on the first two layers and are straightforward to enforce. Furthermore, since the are real numbers enumerated by a single machine, by Claim 14 we can obtain as follows: a pattern is forbidden whenever both and contain at least two symbols (so that encodes an integer , encodes an integer ) and contains a pattern forbidden in .
A configuration is said to be proper. A configuration with is said to be degenerate. Thus, we separate patterns into two categories: whenever only appears in degenerate configurations, we call it a degenerate pattern; if can appear in a proper configuration, we call it a proper pattern.
On the one hand, degenerate patterns of do not contribute much to the number of extender sets, despite being exponentially many:
Claim 16.
Let , and consider , the set of extender sets of degenerate patterns of size . Then .
Proof.
Let be two degenerate patterns. Whenever and , we have because the density layer of such patterns can be anything. Since at most a single symbol can appear on the second layer of degenerate patterns, by counting possibilities for their first layers we obtain .
On the other hand, all proper patterns of belong to distinct extender sets:
Claim 17.
Let be two distinct proper patterns. Then .
Proof.
Let be a proper pattern. It can be extended into a whole proper configuration such that . By definition, is periodic of period : thus, is entirely determined by , and can only extend the pattern itself.
However, there are only polynomially many distinct proper patterns of a given size in . The next section will neverthelesss create a subshift with the correct (exponential) amount of proper patterns, thanks to the following remark:
Claim 18.
-
For an integer and a proper configuration such that , an -period of the density layer contains at most symbols .
-
For integers and , and a proper configuration such that , a factor of length of the density layer contains at most symbols .
Proof.
This follows from Claim 13 and the monotonicity of the sequence .
Free bits in the subshift
To create the desired exponential number of extender sets, we create the subshift by adding free bits on top of the symbols of the density layer. Informally, if there were symbols in an -period of the density layer in , adding free bits on top of the symbols creates patterns in . Thus, we add a fourth layer to :
-
4.
Free layer : We define the free layer as . Given the synchronizing map defined as and , we say that two configurations and are synchronized if .
and we define as:
Claim 19.
The subshift is effective.
Proof.
In addition to the forbidden patterns of , forbid patterns for which and both contain two symbols (in which case, denote by the distance between two symbols in ), but is either not synchronized with or not -periodic.
We extend the terminology from to and call proper the configurations of that encode integers and on their first two layers, and degenerate those who do not. Similarly, a pattern is proper if it can be extended into a proper configuration, and degenerate if it only extends into degenerate configurations.
Since the free layer is required to be -periodic only in proper configurations, Claims 16 and 17 both extend from to by the very same arguments:
Claim 20.
-
For , consider . Then .
-
Let be two distinct proper patterns. Then .
Lemma 21.
Let . Then
Proof: lower bound..
Consider the patterns in for : the number of symbols in the density layer of such is by Claim 13. Since , by taking large enough we obtain a proper pattern such that its density layer contains symbols .
Thus, we obtain proper patterns such that (since each symbol in leads to two distinct patterns in the free layer ).
Proof: upper bound..
To overestimate the number of proper patterns , we consider the restrictions for ranging in the proper configurations of (consider all values of and of -factors in ), and bound the number of symbols in each case: by Claim 18,
-
If , an -period of the density layer contains less than symbols .
-
For , contains less than symbols .
Since each symbol in an -period of the density layer results in two distinct patterns in the free layer, and there are less than possibilities for such periods, we obtain:
6 Extender Entropies for Sofic Subshifts
We now want to extend A to multidimensional sofic shifts: an idea could be to replace -periodic words on in the previous construction with -periodic squares on . Unfortunately, such a subshift cannot be sofic444The argument proving that the classical mirror subshift cannot be sofic still applies here: there would be distinct patterns, but only borders in the SFT cover..
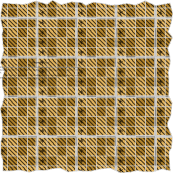
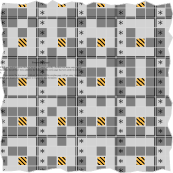
Yet, making configurations periodic is not necessary to ensure that two proper patterns and have distinct extender sets: it is enough to have a configuration that witnesses the difference between and (by extending one but not the other). This was already illustrated in the semi-mirror shift (see Section 3): instead of mirroring the whole half-plane (which is not sofic), non-deterministically reflecting a single bit from the upper to the lower half-plane is actually enough, since each bit can be reflected individually in some configuration. In this section, we use this idea to prove (see Figure 4):
See B
6.1 Preliminary: Marking Offsets With Configurations
In our construction, we will need to mark some positions . To do so, we consider the alphabet . Denote by the -periodic configuration formally defined as if and only if . We say that a symbol is a marker.
For a configuration with , we say that a position is marked if . This lattice has unit cells of size instead of : this is voluntary. In particular, some marked positions satisfy .
Considering the subshift generated by all the configurations , we define:
where is the set of configurations having at most one marker symbol : these are the configurations that appear when taking the closure of all .
6.2 Construction: the Sofic Subshift
Let us now begin a construction to prove B. We use the notations introduced in the proof of A: we fix such that for a computable sequence of real numbers (we assume the same monotonicity properties). We define a subshift on the following five layers:
-
Lifted layers: We define the first three layers of as , where and are the three layers of the subshift defined in the proof of A.
-
Marker layer : We define to mark positions .
-
Free layer : We also define the free layer by .
and we define as (see Figure 5 for an illustration):
Extending the terminology from to , we call proper the configurations of that encode integers and on their first two layers, and degenerate those which do not. Additionally we say that a pattern is proper if it can be extended into a proper configuration, and degenerate otherwise. We say that two proper patterns are similar if they are equal on their first four layers (i.e. ).
Claim 22.
Two similar proper patterns have distinct extender sets if and only if there exists a proper configuration that extends and that marks a position such that .
We would very much like an analog of Claim 20: unfortunately, not all proper patterns generate distinct extender sets. Indeed, by the previous claim, similar proper patterns generate distinct extender sets only when the positions at which they differ can be marked by an extending configuration (this depends on the relative position of an window covering the four quadrants of a square, etc…). Yet, we do not need precise considerations to count the number of extender sets, and simply prove the following bounds:
Lemma 23.
Let . Then
Proof: lower bound..
For , consider the set . The number of symbols in an -period in the density layer of such configurations is by Claim 13. Since , by taking large enough we obtain a set of proper configurations whose density layer contains symbols in an -period.
Considering the free layer of such patterns, there are at least distinct patterns in the finite set , and we claim that they all generate distinct extender sets. Indeed, for any two distinct patterns , there exists a position such that ; and there exists a configuration that extends with : in particular, marks the position .555Markers were chosen to be -periodic for this reason: we need to be able to mark a position in a configuration without seeing a marker in the square . By Claim 22, we obtain . This proves that .
Proof: upper bound..
We proceed as with the effective subshift : to bound the cardinality of , we consider the restrictions for ranging in the proper configurations of (for all values of , , and , and count free layers by Claim 18:
-
If , an square of the density layer contains less than symbols .
-
If , the density layer contains less than symbols .
Finally, when summing over all these cases, we overestimate the number of extender sets generated by the free layer by assuming that each position containing a symbol on the density layer can be marked by a proper configuration extending the pattern (while only a subset of such positions can be marked):
By taking the limit , we obtain that . Thus, we are left to prove:
Claim 24.
The subshift is a sofic subshift.
This proof is very standard and unsurprising, yet is included for the sake of exhaustiveness.
Sketch of proof.
First, we introduce a grid subshift. Let us denote by the subshift on the alphabet defined as the closure of all the square grid configurations (see Figure 6(a)). It is a sofic subshift: by enforcing the continuity of black lines between adjacent positions, we obtain an irregular grid; to obtain a regular square grid, we make each cross 
Let us now synchronize with : we define the set of configurations such that has mesh if and only if encodes some (see Figure 6(b)).
Claim 25.
is a sofic subshift.
Sketch of proof..
Using areas of colors in the SFT cover, ensure that exactly one black vertical line in can appear between two vertical lines of symbols in .
Let us now prove that is a sofic subshift. Intuitively, it follows from Theorem 2: is a “decorated version” of . The most tricky step is in the periodicity condition: periodicity of a free bit in should only be enforced whenever both layers and do not belong in , i.e. whenever they both actually encode some integers and .
To proceed, we slightly alter the subshift to define a new subshift : it contains an additional layer (the proper layer) that can take two values (either or ), and is forced to be whenever both the first and second layer do encode integers:
By a slight alteration of Claim 15, the subshift is effective whenever is a real number. By Theorem 2, the subshift is thus sofic. Then, we use the proper layer to enforce periodicity of a free bit in only whenever , and define as:
Claim 26.
is a sofic subshift.
Sketch of proof..
By the previous paragraph, the first four
layers are sofic; and by Claim 25, the synchronization
of and is sofic. To
make a free bit periodic, one can carry a unique symbol
along the black lines of
in an SFT cover, and enforce the following: on positions
at which a cross symbol 
We can now prove that is sofic. Indeed, fix an SFT cover of in which we color cross symbols 
-
Erase the proper layer.
-
Projection of the grid layer: red crosses become , and all other symbols become .
Indeed, projecting the grid layer as mentioned creates the marker layer . The only condition that remains to be checked is the -periodicity condition on a free bit.
Notice that in , both cases and are possible whenever or , so that erasing the proper layer in the projection merges the two cases together and removes the periodicity enforced a free bit of ; while whenever and , only the case is allowed: so that, when projecting, the periodicity condition is still enforced.
7 Realizing Extender Entropies: Computable Subshifts
A subshift is said to be computable if its language is decidable. Following the proofs from Section 4, one proves that extender entropies of computable subshifts are real numbers. We prove the converse inclusion and obtain:
Theorem 27.
The set of extender entropies of computable effective subshifts (resp. computable sofic subshifts) is exactly .
Sketch of proof.
We slightly alter our previous constructions. The subshift constructed in A might not be computable whenever , since, given some and some factor of , it might be undecidable to know whether when .
Yet, when taking for a computable sequence, the previous problem becomes decidable; thus, the subshift is computable. Both proofs, on and , then go through without any other modification.
8 Extender Sets of Minimal Subshifts
Minimality is a general dynamical notion; in our context, a subshift is minimal if it contains no nonempty proper subshift. Extender sets are much easier in minimal subshifts and do not even depend on the computability of the language:
Proposition 28.
Let be a minimal subshift over . Then for any and any patterns , .
Proof.
Let and suppose that . Then any appearance of in a configuration can be replaced by : by iterating the process while ordering patterns lexicographically (see [23, Lemma 2.2] for the complete argument), we obtain by compactness a configuration of is which does not appear, which contradicts minimality.
This implies that if is minimal. Since minimal sofic subshifts have zero entropy (folklore, see [11, Proposition 6.1]), and minimal effective subshifts have arbitrary entropy (consider [16, Theorem 4.77] with computable sequences ), we obtain:
Corollary 29.
The extender entropy of a minimal sofic subshift is always .
Corollary 30.
The set of extender entropies of minimal effective subshifts is exactly .
9 Extender Sets of Subshifts With Mixing Properties
9.1 Mixing Subshifts
Mixingness is another dynamical notion. In the context of subshifts, mixingness intuitively implies that for any pair of admissible words, there exists a configuration containing both of them at arbitrary positions, provided they are sufficiently far apart:
Definition 31 (Mixing subshift).
A subshift is mixing if
We say that is -mixing for some function if can be taken equal to in the previous definition. When is constant , we simply write that is -mixing.
One could expect that strong mixing conditions would restrict the behaviors of extender sets: indeed, all the examples we mentioned so far either have strong mixing properties (the full shift, SFTs…) and zero extender entropy, or have positive extender entropy but are far from mixing (periodicity, reflected positions, …). However, we show in this section that even very restrictive mixing properties do not imply anything on extender entropies.
Proposition 32.
Let be a one-dimensional subshift. There exists a -mixing subshift with . (Furthermore, if was effective, then can be taken effective.)
Proof.
Let be a subshift, and . Denote . Let us define a subshift over the alphabet (assuming that is a free symbol not in by the same family of forbidden patterns : configurations of are composed of (possibly infinite) words of separated by the safe symbol . Then is -mixing, as for any , we have .
We are left with proving that . First, we need to introduce the notion of follower and predecessor sets: in , the follower and predecessor sets are respectively defined as and . In other words, the follower set (resp. predecessor set) of some word correspond to the set of right-infinite (resp. left-infinite) sequences such that (resp. ) appears in some configuration of .
Let . We prove that:
Lower bound.
The lower bound holds simply because if extends a pattern but not , then also belongs in and still extends but not in , so that .
Upper bound.
For the rightmost inequality, we need to distinguish some cases according to whether a pattern contains a or not.
-
Let that does not contain a symbol . Then
So, for So, for that do not contain a symbol , we have if and only if .
-
Let containing at least a symbol , and let be the first and last positions in at which a symbol appear. Let be respectively and . Since is a safe symbol, is entirely determined by :
Doing a disjunction on these two cases, and over the pairs in the second case (and abusing notations again by denoting and ) we obtain:
As and , and that , we obtain , and conclude that .
9.2 Block-gluing Subshifts
There exists various mixing notions in higher dimension. We formulate our results for block-gluing subshifts:
Definition 33.
Let be a subshift, and be a (weakly) increasing function. We say that is -block-gluing if
Said differently, is -block-gluing if any two square patterns of size can appear at any position as long as they are placed with a gap of size at least between them. As with Definition 31, we will simply write -block-gluing for constant gluing distance .
Proposition 34.
For any , there exists an effective and -block-gluing subshift such that .
Proof.
Notice that the free lift of a -block-gluing subshift to is also -block-gluing. By Claim 8, the free lift preserves the extender entropy: thus, we reduce to the one-dimensional case. We conclude by combining the previous Proposition 32 with A.
References
- [1] Nathalie Aubrun, Sebastián Barbieri, and Emmanuel Jeandel. About the Domino Problem for Subshifts on Groups, pages 331–389. Springer International Publishing, Cham, 2018. doi:10.1007/978-3-319-69152-7_9.
- [2] Nathalie Aubrun and Mathieu Sablik. Simulation of effective subshifts by two-dimensional subshifts of finite type. Acta applicandae mathematicae, 126:35–63, 2013. doi:10.1007/s10440-013-9808-5.
- [3] Sebastián Barbieri, Mathieu Sablik, and Ville Salo. Soficity of free extensions of effective subshifts. Discrete and Continuous Dynamical Systems, 45(4):1117–1149, 2025. doi:10.3934/dcds.2024125.
- [4] Jérôme Buzzi. Subshifts of quasi-finite type. Inventiones mathematicae, 2003. doi:10.1007/s00222-004-0392-1.
- [5] Silvio Capobianco. Multidimensional cellular automata and generalization of Fekete’s lemma. Discrete Mathematics & Theoretical Computer Science (DMTCS), 10(3):95–104, 2008. doi:10.46298/dmtcs.442.
- [6] Julien Destombes. Algorithmic Complexity and Soficness of Shifts in Dimension Two. PhD thesis, Université de Montpellier, 2023. arXiv:2309.12241, doi:10.48550/arXiv.2309.12241.
- [7] Julien Destombes and Andrei Romashchenko. Resource-bounded Kolmogorov complexity provides an obstacle to soficness of multidimensional shifts. Journal of Computer and System Sciences, 128:107–134, 2022. doi:10.1016/j.jcss.2022.04.002.
- [8] Bruno Durand, Andrei Romashchenko, and Alexander Shen. Fixed-point tile sets and their applications. Journal of Computer and System Sciences, 78(3):731–764, 2012. doi:10.1016/j.jcss.2011.11.001.
- [9] Thomas French. Characterizing follower and extender set sequences. Dynamical Systems, 31(3):293–310, 2016. doi:10.1080/14689367.2015.1111865.
- [10] Thomas French and Ronnie Pavlov. Follower, predecessor, and extender entropies. Monatshefte für Mathematik, 188:495–510, 2019. doi:10.1007/s00605-018-1224-5.
- [11] Silvère Gangloff. Algorithmic complexity of growth-type invariants of SFT under dynamical constraints. PhD thesis, Aix-Marseille Université, 2018. URL: http://www.theses.fr/2018AIXM0231/document.
- [12] Pierre Guillon and Emmanuel Jeandel. Infinite communication complexity, 2015. arXiv:1501.05814.
- [13] Michael Hochman. On the dynamics and recursive properties of multidimensional symbolic systems. Inventiones Mathematicae, 176(1):2009, April 2009. doi:10.1007/s00222-008-0161-7.
- [14] Michael Hochman and Tom Meyerovitch. A characterization of the entropies of multidimensional shifts of finite type. Annals of Mathematics, 171(3):2011–2038, 2010. doi:10.4007/annals.2010.171.2011.
- [15] Steve Kass and Kathleen Madden. A sufficient condition for non-soficness of higher-dimensional subshifts. Proceedings of the American Mathematical Society, 141(11):3803–3816, 2013. doi:10.1090/S0002-9939-2013-11646-1.
- [16] Petr Kůrka. Topological and Symbolic Dynamics. Société mathématique de France, 2003.
- [17] Douglas Lind and Brian Marcus. An Introduction to Symbolic Dynamics and Coding. Cambridge university press, 2021.
- [18] Tom Meyerovitch. Growth-type invariants for subshifts of finite type and arithmetical classes of real numbers. Inventiones Mathematicae, 184(3), 2010. doi:10.1007/s00222-010-0296-1.
- [19] Harold Marston Morse and Gustav Arnold Hedlund. Symbolic Dynamics. American Journal of Mathematics, 60(4):815–866, October 1938. doi:10.2307/2371264.
- [20] Shahar Mozes. Tilings, substitution systems and dynamical systems generated by them. Journal d’Analyse Mathématique, 53(1):139–186, 1989. doi:10.1007/bf02793412.
- [21] Nic Ormes and Ronnie Pavlov. Extender sets and multidimensional subshifts. Ergodic Theory and Dynamical Systems, 36(3):908–923, 2016. doi:10.1017/etds.2014.71.
- [22] Ronnie Pavlov. A class of nonsofic multidimensional shift spaces. Proceedings of the American Mathematical Society, 141(3):987–996, 2013. doi:10.1090/S0002-9939-2012-11382-6.
- [23] Anthony N. Quas and Paul B. Trow. Subshifts of multi-dimensional shifts of finite type. Ergodic Theory and Dynamical Systems, 20(3):859–874, 2000. doi:10.1017/S0143385700000468.
- [24] Robert I Soare. Turing computability: Theory and applications, volume 300. Springer, 2016. doi:10.1007/978-3-642-31933-4.
- [25] Hao Wang. Proving theorems by Pattern Recognition II. Bell Systems technical journal, 40:1–41, 1961. doi:10.1002/j.1538-7305.1961.tb03975.x.
- [26] Benjamin Weiss. Subshifts of finite type and sofic systems. Monatshefte für Mathematik, 77:462–474, 1973. doi:10.1007/BF01295322.
- [27] Xizhong Zheng and Klaus Weihrauch. The arithmetical hierarchy of real numbers. Mathematical Logic Quarterly: Mathematical Logic Quarterly, 47(1):51–65, 2001. doi:10.1002/1521-3870(200101)47:1<51::AID-MALQ51>3.0.CO;2-W.