When Alpha-Complexes Collapse onto Codimension-1 Submanifolds

Abstract
Given a finite set of points sampling an unknown smooth surface , our goal is to triangulate based solely on . Assuming is a smooth orientable submanifold of codimension in , we introduce a simple algorithm, Naive Squash, which simplifies the -complex of by repeatedly applying a new type of collapse called vertical relative to . Naive Squash also has a practical version that does not require knowledge of . We establish conditions under which both the naive and practical Squash algorithms output a triangulation of . We provide a bound on the angle formed by triangles in the -complex with , yielding sampling conditions on that are competitive with existing literature for smooth surfaces embedded in , while offering a more compartmentalized proof. As a by-product, we obtain that the restricted Delaunay complex of triangulates when is a smooth surface in under weaker conditions than existing ones.
Keywords and phrases:
Submanifold reconstruction, triangulation, abstract simplicial complexes, collapses, convexityFunding:
Bianca B. Dornelas: Funded by the Austrian Science Fund (FWF), grant W1230.Copyright and License:
 © Dominique Attali, Mattéo Clémot, Bianca B. Dornelas, and André Lieutier; licensed under Creative Commons License CC-BY 4.0
2012 ACM Subject Classification:
Theory of computation Computational geometryEditors:
Oswin Aichholzer and Haitao WangSeries and Publisher:
 Leibniz International Proceedings in Informatics, Schloss Dagstuhl – Leibniz-Zentrum für Informatik
1 Introduction
Given a finite set of points that sample an unknown smooth surface (example in Figure 1(a)), we aim to approximate based solely on . This problem, known as surface reconstruction, has been widely studied [41, 11, 37, 14, 2, 17, 38, 36]. Several algorithms based on computational geometry have been developed, such as Crust [3], PowerCrust [5], Cocone [4], Wrap [27] and variants based on flow complexes [34, 35, 25, 13]. These algorithms rely on the Delaunay complex of and offer theoretical guarantees, summarized in [23].
The most desirable guarantee is that the reconstruction outputs a triangulation of , that is, a simplicial complex whose support is homeomorphic to , in which case we call the algorithm topologically correct. That has been established for many of the aforementioned algorithms, assuming that is noiseless () and sufficiently dense. Specifically, let be a lower bound on the reach of , and an upper bound on the distance between any point of and its nearest point in . Both Crust and Cocone are topologically correct under the condition [24], which, to our knowledge, is the weakest such constraint guaranteeing topological correctness for surface reconstruction algorithms in .
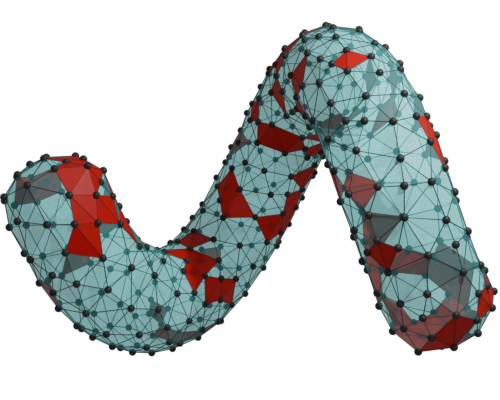
Surface reconstruction generalizes to approximating an unknown smooth submanifold from a finite sample . One approach in that case, similar to the Wrap algorithm in , involves collapses, which are typically applied to complexes like the -complex [12]. The -complex of [31, 28, 29] includes simplices whose circumspheres have radius and enclose no other points of [30]. For well-chosen , the -complex has the same homotopy type as [40, 18, 19, 8], provided that is sufficiently dense and has low noise relative to the reach of . However, it may still fail to capture the topology of , as illustrated in Figure 1(b): for , the -complex of includes slivers, tetrahedra that have one dimension more than , preventing the existence of a homeomorphism. Slivers complicate reconstructing -dimensional submanifolds in for for all Delaunay-based reconstruction attempts.
Contributions.
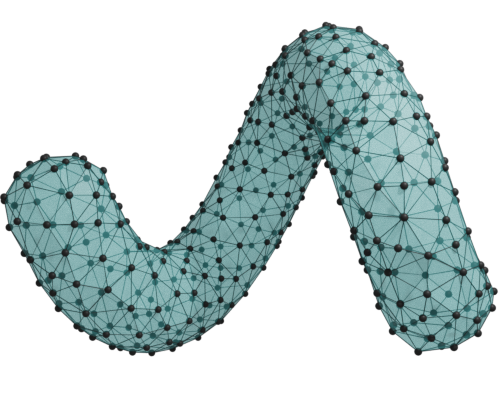
We introduce a simple algorithm, NaiveVerticalSimplification, which takes as input a simplicial complex and simplifies it by applying collapses guided by the knowledge of . We call it naive because this knowledge is non-realistic in practice. We find conditions under which the algorithm is topologically correct for smooth orientable submanifolds of with codimension one. Its variant, PracticalVerticalSimplification, does not rely on and remains topologically correct, though it requires stricter conditions. When applying both algorithms to the -complex of and returning the result, we obtain two reconstruction algorithms which we refer to as and , respectively. We determine conditions on the inputs and that guarantee the topological correctness of these squash algorithms. Moreover, for , we show that is correct under the sampling condition (see Figure 1(c) for an example output), while is correct for , assuming suitable choice of . We also show that the restricted Delaunay complex [16] is generically homeomorphic to when .
In addition, while proving these results, we derive an upper bound for when triangles with vertices on a smooth submanifold form a small angle with : for a triangle with , longest edge , and circumradius , we show that the angle between the affine space spanned by and the tangent space to at satisfies:
| (1) |
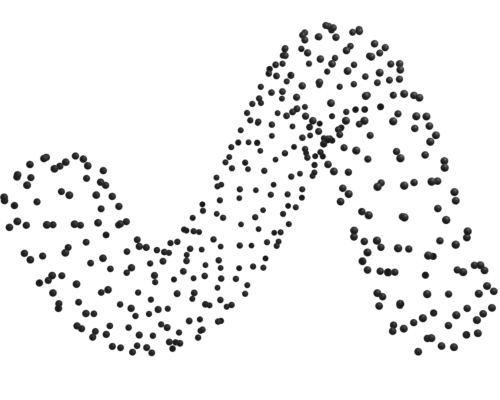
Techniques.
Our proof of correctness for the squash algorithms is more compartmentalized than the ones present in the literature: we first consider a smooth orientable submanifold with codimension one and a general simplicial complex embedded in and contained within a small tubular neighborhood of . We introduce vertical collapses (relative to ) in which remove -simplices of that either have no -simplices of above them in directions normal to or no -simplices of below them in directions normal to . NaiveVerticalSimplification iteratively applies vertical collapses relative to . PracticalVerticalSimplification does not depend on knowledge of and applies vertical collapses relative to a hyperplane, constructed dynamically based on the simplex currently considered for collapse.
We examine conditions for the correctness of these algorithms. Apart from the requirement that has no vertical -simplices relative to for and that its support projects onto and fully covers it, we require the vertical convexity of relative to . This means that each normal line to at a point (restricted to a small ball around ) intersects the support of in a convex set. For PracticalVerticalSimplification, an additional requirement is that the -simplices of must form an angle of at most with .
Afterwards, we present and , which initialize the previous algorithms with as the -complex of a point set that samples . We show that correctness is guaranteed when the -simplices in the -complex form small angles with for . We provide explicit upper bounds for these angles, expressed in terms of , , and , where and control the sample density and noise in .
We analyze the case and provide numerical bounds on the ratios and that ensure the correctness of both squash algorithms. Instrumental to this step, we derive (1) which enables us to upper bound the angles of triangles in the -complex relative to the manifold and is of independent interest.
Related work.
The Squash algorithms (both practical and naive) are similar to Wrap [31, 12] in that they compute a subcomplex of the Delaunay complex of and then perform a sequence of collapses. However, the selection of and the nature of the collapses differ between the two methods: in the naive squash, definitions are relative to , unlike Wrap, which uses flow lines derived from to guide the collapsing sequence. This distinction allows us to address the general case first and then focus on the specific case of the -complex. Moreover, while we guarantee correctness for a larger interval of the ratio compared to previous literature, most existing work addresses non-uniform sampling cases, whereas our work focuses on uniform sampling.
The vertical convexity assumption, crucial for the correctness of our algorithms, has been employed in various forms to establish collapsibility of certain classes of simplicial complexes [1, 20, 10]. Similarly, bounding the angle between the manifold and the simplices used for reconstruction has been essential in prior work [23, 22, 21, 6, 9]. Our bound (1) remains true when replacing with the local feature size of , as explained in [7, App. A]. The thus modified bound improves upon the known bound [23, Lemma 3.5].
At last, for , we show in the full version [7] that the restricted Delaunay complex is generically homeomorphic to for . In contrast, it is proven to be homeomorphic to only if [22, Theorem 13.16], a result based on the Topological Ball Theorem [22, Theorem 13.1]. Our proof bypasses this requirement, relying instead on .
Outline.
After the preliminaries in Section 2, Section 3 defines vertically convex simplicial complexes. We introduce the concepts of upper and lower skins for these complexes and prove that both are homeomorphic to their orthogonal projection onto . Section 4 presents general conditions under which a simplicial complex can be transformed into a triangulation of through either Naive or Practical vertical simplification. Section 5 provides conditions ensuring the topological correctness of both the naive and practical Squash algorithms and the restricted Delaunay complex. All missing proofs can be found in the full version [7].
2 Preliminaries
Subsets and submanifold
Given a subset , we define several important geometric concepts. The convex hull of is denoted as and the affine space spanned by as . The interior of is denoted as . The relative interior of , denoted as , represents the interior of within . For any point and radius , we denote the closed ball with center and radius as . The -offset of , denoted as , is the union of closed balls centered at each point in with radius : . The medial axis of , denoted as , is the set of points in that have at least two nearest points in . The reach of , denoted as , is the infimum of distances between and . Furthermore, we define the projection map , which associates each point with its unique closest point in . This projection map is well-defined on every subset of that does not intersect , particularly on every -offset of with .
Throughout the paper, we designate as a compact submanifold of of codimension one, and, therefore, orientable (see e.g. [42]).
Given , we denote the affine tangent space to at as and the affine normal space as . As has codimension one, is a hyperplane and is a line. Additionally, since is , it has a positive reach [43]. For all real numbers such that , the -offset of can be partitioned into the set of normal segments [26], that is,
We define as a differentiable field of unit normal vectors of [26]. We let be a finite arbitrary number such that , fixed throughout.
Abstract simplicial complexes and collapses
We recall some classical definitions of algebraic topology [39, 29]. An abstract simplicial complex is a collection of finite non-empty sets with the property that if belongs to , so does every non-empty subset of . Each element of is called an abstract simplex and its dimension is one less than its cardinality: . A simplex of dimension is called an -simplex and the set of -simplices of is denoted as . If and are two simplices such that , then is called a face of , and is called a coface of . The -dimensional faces of are the facets of . The vertex set of is . A subcomplex of is a simplicial complex whose elements belong to . The link of in , denoted , is the set of simplices in such that and . It is a subcomplex of . The star of in , denoted as , is the set of cofaces of . The simplicial complex formed by all the faces of is the closure of , .
Consider next an abstract simplex . One can associate it to the geometric simplex , called the support of . In general, and we say that is non-degenerate whenever . Given a simplicial complex with vertices in , we say that is canonically embedded if the following two conditions are satisfied:
-
1.
for all ;
-
2.
for all .
In this paper we consider exclusively abstract simplicial complexes with vertex sets in and which are canonically embedded.
Given such a simplicial complex, its underlying space (or support) is the point set . If is homeomorphic to , then is called a triangulation of or is said to triangulate . Since is canonically embedded, the link of every -simplex of falls into one of the following two categories: (1) it is a triangulation of the sphere of dimension or (2) it is a proper111A proper subset of is such that . subcomplex of such a triangulation. The boundary complex of a simplicial complex is the subset of simplices in the second category, denoted , and it holds that . Simplices in are referred to as boundary simplices of . Given a set of abstract simplices , if has no coface in besides itself, then is said to be inclusion-maximal in .
Suppose that is a simplex whose star in has a unique inclusion-maximal element . Then is said to be free in . Equivalently, is free in if and only if the link of in is the closure of a simplex. Consequently, free simplices of are always boundary simplices of . However, not all boundary simplices of are necessary free. There are instances where none of them are free, such as the famous example when triangulates the 2-dimensional subspace of , known as the “house with two rooms”. A collapse in is the operation that removes from a free simplex along with all its cofaces. This operation is known to preserve the homotopy-type of .
Delaunay complexes, -complexes, and -shapes
Consider a finite collection of points . The Voronoi region of is the collection of points that are closer to than to any other points of :
Given a subset , let . The Delaunay complex is defined as
A simplex is called a Delaunay simplex of and it is dual to its corresponding Voronoi cell . Henceforth, we assume that the set of points is in general position. This means that no points of lie on the same -dimensional sphere and no points of lie on the same -dimensional flat for . In that case, is canonically embedded [33]. For , the -complex of is the subcomplex of defined by:
Its underlying space is called the -shape of . It has the properties: (i) and (ii) is homotopy equivalent to ; see [28] for more details.
3 Vertically convex simplicial complexes
In this section, we define the concept of vertical convexity relative to for both a set and a simplicial complex. We then study the boundary of a vertically convex simplicial complex . Specifically, we divide the boundary of its underlying space into an upper and a lower skins, enabling us to identify two boundary subcomplexes: an upper and a lower ones. Furthermore, we show that each of these subcomplexes triangulates the orthogonal projection of onto (Lemma 6). We also extend the definitions for a single -simplex.
Definition 1 (Vertical convexity).
A set is vertically convex relative to if such that
-
1.
and
-
2.
, is convex.
In other words, for any , the set is either empty or a line segment (possibly of zero-length). A simplicial complex is vertically convex relative to if its underlying space is.
Examples of a non-vertically convex and a vertically convex simplicial complexes are provided in Figures 2 and 3, respectively.
3.1 Upper and lower skins
Assume that is vertically convex relative to and let . The endpoints (possibly equal) of the segment are denoted by and , with being above along the direction of the unit normal vector . With this notation, can be expressed as a union of disjoint normal segments:
The upper skin and lower skin of are, respectively:
Figure 3 displays an example. Our goal is to study the skins of , for which we need two extra definitions.
Definition 2 (Vertical simplex).
A simplex such that is vertical relative to if there exists a pair of distinct points in sharing the same projection onto .
Definition 3 (Non-vertical skeleton).
Assume that . We say that has a non-vertical skeleton relative to if contains no vertical -simplices relative to for all integers .
The next lemma is a key property of vertically convex simplicial complexes:
Lemma 4.
Suppose that is vertically convex and has a non-vertical skeleton relative to . Then, the upper and lower skins of are closed sets, each homeomorphic to . The homeomorphism is realized in both cases by . In addition,
| (2) |
A simple consequence follows:
Lemma 5.
Let be vertically convex and with non-vertical skeleton relative to . If , then .
Aiming for a simplicial version of Equation (2), we define the upper complex of and the lower complex of relative to as follows:
By construction, both are subcomplexes of . A combinatorial equivalent of Lemma 4 is:
Lemma 6.
Let be vertically convex with non-vertical skeleton relative to . Then,
Moreover, if , both and are triangulations of .
3.2 Upper and lower facets of a -simplex
Let be a non-degenerate -simplex of such that for some . In that case, is embedded and vertically convex relative to . The facets of can be partitioned into upper facets and lower facets of relative to as follows:
An example can be seen in Figure 4, where one can also observe the following property:
Lemma 7.
Consider a non-degenerate -simplex such that for some . If has no vertical facets relative to , then and are non-empty sets that partition the facets of .
4 Vertically collapsing simplicial complexes
In this section, assuming that for some , we introduce an algorithm for simplifying using vertical collapses relative to (Section 4.1) and establish conditions for when it outputs a triangulation of (Section 4.2). We first present a naive version that requires the knowledge of and then present a practical version (Section 4.3).
4.1 Naive algorithm
Definition 8 (Vertically free simplices).
A simplex is said to be free from above (resp., free from below) in relative to if
-
is a free simplex of ;
-
the unique inclusion-maximal simplex in has dimension ;
-
the set of -simplices in is exactly the set of upper (resp., lower) facets of relative to .
We say that is vertically free in relative to if is either free from above or from below in relative to . See Figures 5 and 7 for a depiction.
Remark 9.
Definition 10 (Vertical collapse).
A vertical collapse of relative to is the operation of removing the star of a simplex that is vertically free relative to .
A vertical collapse of can be seen as compressing the underlying space of by shifting its upper or lower skin along directions normal to ; see Figure 5. Our first algorithm, outlined in Algorithm 1, simplifies by iteratively applying vertical collapses relative to . It is worth noting that the algorithm operates on any simplicial complex with for , irrespective of whether is vertically convex relative to or not.
4.2 Correctness
We now establish conditions under which transforms into a triangulation of . For that, we introduce a binary relation over -simplices:
Definition 11 (Below relation ).
Let be two -simplices sharing a common facet and let for some . We say that is below (or that is above ) relative to , denoted , if is an upper facet of and a lower facet of relative to .
Note that the relation is not acyclic in general, see Figure 6.
Theorem 12 (Correctness).
Consider such that for some and assume the following:
- Injective projection:
-
has a non-vertical skeleton relative to .
- Covering projection:
-
.
- Vertical convexity:
-
is vertically convex relative to .
- Acyclicity:
-
is acyclic over -simplices of .
Then, transforms into a triangulation of .
The remaining of this section aims to prove Theorem 12 and we consider such that for some . Using the relation , associate to its dual graph that has one node for each -simplex of and one arc for each pair of -simplices that share a common facet . Direct an arc from to if , and from to otherwise. Since either or , this yields a well-defined orientation for each arc in the dual graph. Figures 6 and 7 show examples.
In a directed graph, a source is a node with only outgoing arcs, while a sink is a node with only incoming arcs. The next lemma states that a vertical collapse in corresponds to the removal of either a sink or a source in and conversely. For that, given a finite set of abstract simplices , let denote the set of vertices that belong to all simplices in . If , it forms an abstract simplex.
Lemma 13 (Sinks and sources).
Consider such that for some and assume that satisfies the injective projection, covering projection and vertical convexity assumptions of Theorem 12. Consider a -simplex and let and . Then,
-
is a free simplex of from above relative to is a sink of .
-
is a free simplex of from below relative to is a source of .
The next lemma provides an invariant for the while-loop of Algorithm 1.
Lemma 14 (Loop invariant).
Consider such that for some . Let be a vertically free simplex in relative to . Let be obtained from by collapsing in . If satisfies the assumptions of Theorem 12, then so does .
Lemma 15 (Upon termination).
Consider such that for some and assume that satisfies the injective projection and vertical convexity assumptions of Theorem 12. If , then .
Proof.
We establish the contrapositive:
Suppose that the two skins are distinct, in other words, that there exists such that and let us show that the segment intersects the support of at least one -simplex of , implying . Suppose, for a contradiction, that only intersects the support of -simplices of for . As and has a finite number of simplices, at least one of these -simplices, say , intersects in a non-zero length segment containing distinct points . Hence, and share the same orthogonal projection onto , implying that is vertical relative to . This contradicts the injective projection assumption on and therefore establishes the contrapositive.
We now prove the correctness of .
Proof of Theorem 12..
The algorithm starts with that satisfies the theorem assumptions. By Lemma 14, after each iteration of the while-loop we obtain a new that continues to satisfy those assumptions. Since each iteration involves a vertical collapse of relative to , the number of -simplices of is reduced. Thus, the algorithm must terminate. Upon termination, there are no vertically free simplices in relative to . By Lemma 13, this implies that, when Algorithm 1 terminates, has no terminal node (neither a source nor a sink) and is therefore empty. By Lemma 15, it follows that . By Lemma 5, we have and Lemma 6 implies
with being a triangulation of .
4.3 Practical version
Algorithm 1 relies on knowledge of , which renders it impractical for implementation since is typically unknown. In this section, we introduce Algorithm 2, a feasible variant that is correct if the -simplices of form a sufficiently small angle with ; see [7, App. A] for a definition of the angle between affine spaces. In this variant, we assign an affine space to each : for a free simplex with a -dimensional coface , is defined as the hyperplane spanned by any facet of . Otherwise, set . We also use the notion of vertically free simplices relative to , extending Definition 8 as indicated in Remark 9.
Theorem 16 (Correctness).
Suppose that satisfies the assumptions of Theorem 12 and, in addition, for all -simplices of
| (3) |
Then, transforms into a triangulation of .
5 Correct reconstructions from -complexes
In this section, we assume that is sampled by a finite point set and consider Algorithms 3 and 4, which apply vertical collapses to either straightforwardly or practically. We introduce two parameters, and , to control the sample density and noise of , respectively, and a scale parameter . Section 5.1 establishes conditions ensuring the correctness of Algorithms 3 and 4, with the proof outlined in Section 5.2. Section 5.3 shows how these conditions hold for a wide range of and when is a surface in and is noiseless. This result is extended to the restricted Delaunay complex of in Section 5.4.
5.1 Sampling and angular conditions in
The next definition enables us to express our results in more concisely.
Definition 17 (Strict homotopy condition).
We say that satisfy the strict homotopy condition if for and for .
Let be an interval of values so that is vertically convex with relation to . The exact definition can be found in [7, App. D.1]. The fact that this interval guarantees vertical convexity follows from the specialization of Propositions and in [8] to the case where has codimension-one:
Theorem 18 (Specialization of [8]).
Suppose that and with that satisfy the strict homotopy condition. Then, for all , and is vertically convex relative to . Thus, has associated upper and lower skins and deformation-retracts onto along . In addition, the two skins partition .
The above concepts can be put together to state our main theorem:
Theorem 19.
Assume and for that satisfy the strict homotopy condition. Let and such that . Suppose that for all -simplices , and all -simplices it holds:
| (4) | ||||
| (5) | ||||
| (6) |
Then, satisfies the injective projection, covering projection, vertical convexity and acyclicity assumptions of Theorem 12. Furthermore, both the upper and lower complexes of relative to are triangulations of and returns a triangulation of .
Corollary 20.
Suppose the assumptions of Theorem 19 are satisfied and furthermore that for all -simplices ,
| (7) |
Then, returns a triangulation of .
5.2 Partial proof technique for Theorem 19
In this section, we establish the covering projection and vertical convexity of , as guaranteed by Theorem 19. The complete proof of that theorem, which is unfortunately too lengthy to include here, can be found in [7, App. E].
Lemma 21.
Upper and lower joins.
For proving this lemma, we introduce upper and lower joins. Consider , , , , and that satisfy the assumptions of Lemma 21 and notice that they also meet the conditions of Theorem 18. Therefore, has associated upper and lower skins and the two skins form a partition of . Using that partition, we decompose the set difference into upper and lower joins, slightly adapting what is done in [28]; see Figures 2 and 8. For that, notice that can be decomposed into faces, each face being the restriction of to a Voronoi cell of . There is a one-to-one correspondence between simplices of and faces of : the simplex corresponds to the face and conversely. We can further partition each face of into a portion that lies on the upper skin of and a portion that lies on the lower skin of . Note that or can be empty. We refer to as an upper face and as a lower face. The set of upper faces decompose the upper skin, while the set of lower faces decompose the lower skin. A join is defined as the set of segments where and [28]. We call an upper join and a lower join. The next lemma, proved in [7, App. E.2], identifies points in that are connected to upper or lower joins.
Remark 22.
The collection of upper and lower joins cover the set .
Remark 23.
If an upper join and a lower join have a non-empty intersection, the common intersection belongs to .
Lemma 24.
Under the assumptions of Lemma 21, let and . If for some (resp. ), the segment lies outside , then it intersects an upper (resp. lower join).
Proof of Lemma 21.
Consider , , , , and that satisfy the assumptions of Lemma 21. As noted before, they also meet the conditions of Theorem 18. Therefore, and is vertically convex relative to . Hence, there exists such that and is a line segment for any . Fix arbitrarily. We show that is also a line segment.
First, we show by contradiction that it is non-empty. Let (resp. ) be the endpoint of the segment that lies on the upper (resp. lower) skin of and hence is contained in an upper (resp. lower) join. By Remark 22, the entire segment is covered by upper and lower joins. Thus, at some point of , an upper join and a lower join intersect. By Remark 23, such an intersection places on as well.
Second, we show by contradiction that is connected. Suppose that are such that with being above along the direction of . Since and is vertically convex, the segment is contained in . By Remark 22, the entire segment is covered by upper and lower joins. Let and be the simplices of that contain and , respectively, in their relative interior. Letting , then both segments and lie outside . It follows, by Lemma 24, that there are at least one lower and one upper joins among the joins that cover ; see Figure 9. Hence, an upper and a lower joins intersect at a point of the segment . By Remark 23, lies in , a contradiction. Therefore, for all , is non-empty and connected, thus forming a line segment.
5.3 Sampling conditions for surfaces in
Theorem 19 requires that the -simplices of form a small angle with the manifold , for . Ensuring this can be challenging in practice, especially for . However, in the specific case of noiseless edges () or triangles (), it is possible to upper bound the angle these simplices form with . For edges, it is known that:
Lemma 25 ([15, Lemma 7.8]).
If is a non-degenerate edge with , then
For triangles, let be the radius of the smallest -sphere circumscribing . We establish a simple bound that is tighter than the previous one (see [23, Lemma 3.5]):
Lemma 26.
If is a non-degenerate triangle with longest edge , for , then
| if is an obtuse triangle and | ||||
| if is an acute triangle. |
If is obtuse, the bound is tight and happens when is a sphere of radius .
The proof is technical and is therefore provided in [7, App. A]. For the same reason, the proof of the following result, where we use the bounds for edges and triangles to establish sampling conditions for surfaces in , is in [7, App. F]. Let us define
which is one particular value of that guarantees ; see [7, App. D.2].
Theorem 27.
Let be a surface in whose reach is at least . Let be a finite point set such that .
-
1.
For all that satisfy ,
-
the upper and lower complexes of relative to are triangulations of ;
-
returns a triangulation of .
-
-
2.
For all that satisfy in addition ,
-
returns a triangulation of .
-
Remark 28.
5.4 The restricted Delaunay complex
We recall from [32] that the restricted Delaunay complex is
Theorem 29.
Let be a surface in whose reach is at least . Let be a finite set such that for . Under the additional generic assumption that all Voronoi cells of intersect transversally, is a triangulation of .
References
- [1] Karim Adiprasito and Bruno Benedetti. Barycentric subdivisions of convex complexes are collapsible. Discrete & Computational Geometry, 64(3):608–626, 2020. doi:10.1007/S00454-019-00137-3.
- [2] Marc Alexa, Johannes Behr, Daniel Cohen-Or, Shachar Fleishman, David Levin, and Claudio T Silva. Point set surfaces. In Proceedings Visualization, 2001. VIS’01., pages 21–29. IEEE, 2001. doi:10.1109/VISUAL.2001.964489.
- [3] N. Amenta and M. Bern. Surface reconstruction by Voronoi filtering. Discrete and Computational Geometry, 22(4):481–504, 1999. doi:10.1007/PL00009475.
- [4] Nina Amenta, Sunghee Choi, Tamal K. Dey, and Naveen Leekha. A simple algorithm for homeomorphic surface reconstruction. Int. J. Comput. Geom. Appl., 12(1-2):125–141, 2002. doi:10.1142/S0218195902000773.
- [5] Nina Amenta, Sunghee Choi, and Ravi Krishna Kolluri. The power crust. In David C. Anderson and Kunwoo Lee, editors, Sixth ACM Symposium on Solid Modeling and Applications, Sheraton Inn, Ann Arbor, Michigan, USA, June 4-8, 2001, pages 249–266. ACM, 2001. doi:10.1145/376957.376986.
- [6] D. Attali and A. Lieutier. Flat delaunay complexes for homeomorphic manifold reconstruction, 2022. arXiv:2203.05943.
- [7] Dominique Attali, Mattéo Clémot, Bianca B. Dornelas, and André Lieutier. When alpha-complexes collapse onto codimension-1 submanifolds, 2024. doi:10.48550/arXiv.2411.10388.
- [8] Dominique Attali, Hana Dal Poz Kouřimská, Christopher Fillmore, Ishika Ghosh, André Lieutier, Elizabeth Stephenson, and Mathijs Wintraecken. Tight bounds for the learning of homotopy à la Niyogi, Smale, and Weinberger for subsets of Euclidean spaces and of Riemannian manifolds. In Proc. 26th Ann. Sympos. Comput. Geom., Athens, Greece, june 11-14 2024.
- [9] Dominique Attali and André Lieutier. Delaunay-like triangulation of smooth orientable submanifolds by -norm minimization. In Xavier Goaoc and Michael Kerber, editors, 38th International Symposium on Computational Geometry, SoCG 2022, June 7-10, 2022, Berlin, Germany, volume 224 of LIPIcs, pages 8:1–8:16. Schloss Dagstuhl – Leibniz-Zentrum für Informatik, 2022. doi:10.4230/LIPIcs.SoCG.2022.8.
- [10] Dominique Attali, André Lieutier, and David Salinas. When convexity helps collapsing complexes. In SoCG 2019-35th International Symposium on Computational Geometry, page 15, 2019.
- [11] Håvard Bakke Bjerkevik. Tighter bounds for reconstruction from -samples. In Xavier Goaoc and Michael Kerber, editors, 38th International Symposium on Computational Geometry (SoCG 2022), volume 224 of Leibniz International Proceedings in Informatics (LIPIcs), pages 9:1–9:17, Dagstuhl, Germany, 2022. Schloss Dagstuhl – Leibniz-Zentrum für Informatik. doi:10.4230/LIPIcs.SoCG.2022.9.
- [12] Ulrich Bauer and Herbert Edelsbrunner. The morse theory of čech and delaunay complexes. Transactions of the American Mathematical Society, 369(5):3741–3762, 2017.
- [13] Ulrich Bauer and Fabian Roll. Wrapping cycles in delaunay complexes: Bridging persistent homology and discrete morse theory. In Wolfgang Mulzer and Jeff M. Phillips, editors, 40th International Symposium on Computational Geometry (SoCG 2024), volume 293 of Leibniz International Proceedings in Informatics (LIPIcs), pages 15:1–15:16, Dagstuhl, Germany, 2024. Schloss Dagstuhl – Leibniz-Zentrum für Informatik. doi:10.4230/LIPICS.SOCG.2024.15.
- [14] Fausto Bernardini, Joshua Mittleman, Holly Rushmeier, Cláudio Silva, and Gabriel Taubin. The ball-pivoting algorithm for surface reconstruction. IEEE transactions on visualization and computer graphics, 5(4):349–359, 1999. doi:10.1109/2945.817351.
- [15] Jean-Daniel Boissonnat, Frédéric Chazal, and Mariette Yvinec. Geometric and topological inference, volume 57. Cambridge University Press, 2018.
- [16] Jean-Daniel Boissonnat, Ramsay Dyer, Arijit Ghosh, and Steve Oudot. Equating the witness and restricted Delaunay complexes. Research Report CGL-TR-24, CGL, November 2011. URL: https://inria.hal.science/hal-00772486.
- [17] Jonathan C Carr, Richard K Beatson, Jon B Cherrie, Tim J Mitchell, W Richard Fright, Bruce C McCallum, and Tim R Evans. Reconstruction and representation of 3d objects with radial basis functions. In Proceedings of the 28th annual conference on Computer graphics and interactive techniques (SIGGRAPH 2001), pages 67–76, 2001. doi:10.1145/383259.383266.
- [18] F. Chazal, D. Cohen-Steiner, and A. Lieutier. A sampling theory for compact sets in Euclidean space. Discrete and Computational Geometry, 41(3):461–479, 2009. doi:10.1007/S00454-009-9144-8.
- [19] F. Chazal and A. Lieutier. Smooth Manifold Reconstruction from Noisy and Non Uniform Approximation with Guarantees. Computational Geometry: Theory and Applications, 40:156–170, 2008. doi:10.1016/J.COMGEO.2007.07.001.
- [20] Aaron Chen, Florian Frick, and Anne Shiu. Neural codes, decidability, and a new local obstruction to convexity. SIAM Journal on Applied Algebra and Geometry, 3(1):44–66, 2019. doi:10.1137/18M1186563.
- [21] Siu-Wing Cheng, Tamal K Dey, and Edgar A Ramos. Manifold reconstruction from point samples. In SODA, volume 5, pages 1018–1027, 2005. URL: http://dl.acm.org/citation.cfm?id=1070432.1070579.
- [22] Siu-Wing Cheng, Tamal Krishna Dey, Jonathan Shewchuk, and Sartaj Sahni. Delaunay mesh generation. CRC Press Boca Raton, 2013.
- [23] Tamal K Dey. Curve and surface reconstruction: algorithms with mathematical analysis, volume 23. Cambridge University Press, 2006.
- [24] Tamal K Dey. Curve and surface reconstruction. In Handbook of Discrete and Computational Geometry, pages 915–936. Chapman and Hall/CRC, 2017.
- [25] Tamal K Dey, Joachim Giesen, Edgar A Ramos, and Bardia Sadri. Critical Points of the Distance to an -Sampling of a Surface and Flow-Ccomplex-Based Surface Reconstruction. International Journal of Computational Geometry & Applications, 18, 2008.
- [26] M. P. do Carmo. Differential Geometry of Curves and Surfaces. Prentice Hall, Upper Saddle River, New Jersey, 1976.
- [27] Herbert Edelsbrunner. Surface reconstruction by wrapping finite sets in space. Discrete and computational geometry: the Goodman-Pollack Festschrift, pages 379–404, 2003.
- [28] Herbert Edelsbrunner. Alpha shapes-a survey. In R. van de Weygaert, G. Vegter, J. Ritzerveld, and V. Icke, editors, Tessellations in the Sciences: Virtues, Techniques and Applications of Geometric Tilings. Springer, 2011.
- [29] Herbert Edelsbrunner and John L. Harer. Computational topology. American Mathematical Society, Providence, RI, 2010. An introduction. doi:10.1090/mbk/069.
- [30] Herbert Edelsbrunner, David G. Kirkpatrick, and Raimund Seidel. On the shape of a set of points in the plane. IEEE Trans. Inf. Theory, 29(4):551–558, 1983. doi:10.1109/TIT.1983.1056714.
- [31] Herbert Edelsbrunner and Ernst P Mücke. Three-dimensional alpha shapes. ACM Transactions On Graphics (TOG), 13(1):43–72, 1994. doi:10.1145/174462.156635.
- [32] Herbert Edelsbrunner and Nimish R Shah. Triangulating topological spaces. International Journal of Computational Geometry & Applications, 7(04):365–378, 1997. doi:10.1142/S0218195997000223.
- [33] Steven Fortune. Voronoi diagrams and delaunay triangulations. In Jacob E. Goodman and Joseph O’Rourke, editors, Handbook of Discrete and Computational Geometry, Second Edition, pages 513–528. Chapman and Hall/CRC, 2004. doi:10.1201/9781420035315.ch23.
- [34] Joachim Giesen and Matthias John. Surface reconstruction based on a dynamical system. Computer graphics forum, 21(3):363–371, 2002. doi:10.1111/1467-8659.00596.
- [35] Joachim Giesen and Matthias John. The flow complex: a data structure for geometric modeling. In SODA, volume 3, pages 285–294, 2003. URL: http://dl.acm.org/citation.cfm?id=644108.644157.
- [36] Simon Giraudot, David Cohen-Steiner, and Pierre Alliez. Noise-adaptive shape reconstruction from raw point sets. Computer Graphics Forum, 32(5):229–238, 2013. doi:10.1111/CGF.12189.
- [37] Hugues Hoppe, Tony DeRose, Tom Duchamp, John McDonald, and Werner Stuetzle. Surface reconstruction from unorganized points. In Proceedings of the 19th annual conference on computer graphics and interactive techniques (SIGGRAPH), pages 71–78, 1992. URL: https://dl.acm.org/citation.cfm?id=134011.
- [38] Michael Kazhdan, Matthew Bolitho, and Hugues Hoppe. Poisson surface reconstruction. Computer Graphics Forum, 7(4), 2006.
- [39] J.R. Munkres. Elements of algebraic topology. Perseus Books, 1993.
- [40] P. Niyogi, S. Smale, and S. Weinberger. Finding the Homology of Submanifolds with High Confidence from Random Samples. Discrete Computational Geometry, 39(1-3):419–441, 2008. doi:10.1007/S00454-008-9053-2.
- [41] Stefan Ohrhallinger, Jiju Peethambaran, Amal Dev Parakkat, Tamal K Dey, and Ramanathan Muthuganapathy. 2d points curve reconstruction survey and benchmark. Computer Graphics Forum, 40(2):611–632, 2021. doi:10.1111/CGF.142659.
- [42] Hans Samelson. Orientability of hypersurfaces in . Proceedings of the American Mathematical Society, 22(1):301–302, 1969.
- [43] Sebastian Scholtes. On hypersurfaces of positive reach, alternating Steiner formulae and Hadwiger’s problem. arXiv preprint, April 2013. arXiv:1304.4179.